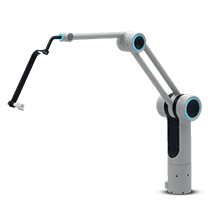
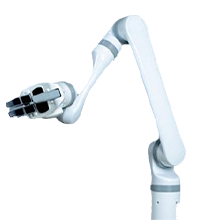
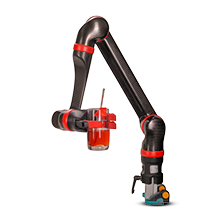
A large research and development project was performed on behalf of (LSR) Munich. The humanoid robot project involved the mechanical fabrication of the robot and the design and implementation of real-time robot control.
Project assumptions:
the range of movements of the robot is to reflect the movements of a human hand
the dimensions of the main parts of the robot are similar to those of a human hand
the weight of the robot should be as low as possible to achieve the required speed of movements and at the same time the required strength
the optimal speed of movements while maintaining the required strength
control.
The design uses:
harmonic gears and high-resolution encoders in all joints
reduced anthropomorphic kinematics with two degrees of freedom
torque / speed / position control with 1kHz frequency